

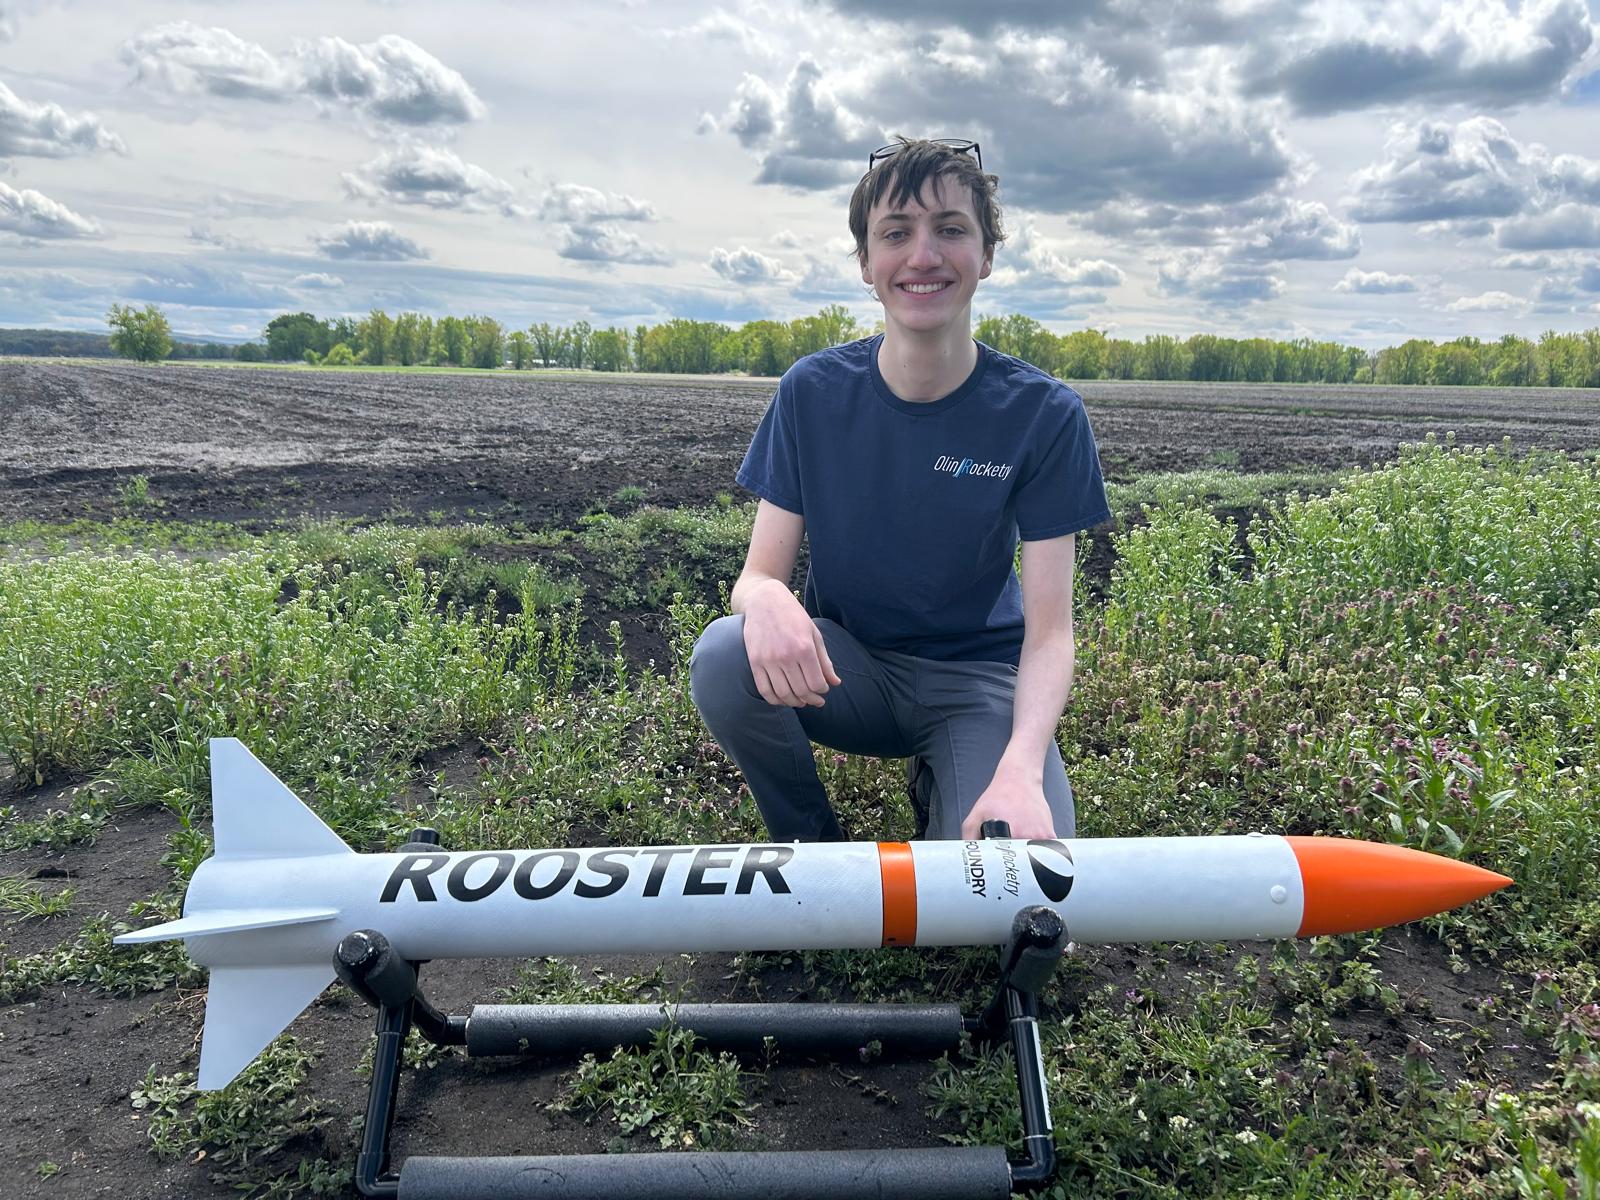
I am a mechanical engineering student at Olin College of Engineering. I'm passionate about rail transit and aerospace. I'm the project manager of Olin Rocketry, where I'm leading an entirely student run project team. I spent this past summer at SpaceX on the Dragon Structures team analyzing the exterior composite structures. The previous summer I was a hardware intern for Frontier Machines, a startup focused on training AI assembly line robotics.
I have experience in machining, design/modeling, and simulation/systems. I spend my free time working to restore controls from retired AEM-7 electric locomotives which I am currently integrating into a custom simulator. While my primary interest is focused on mechanical systems, I also enjoy designing and integrating electronics into my work.
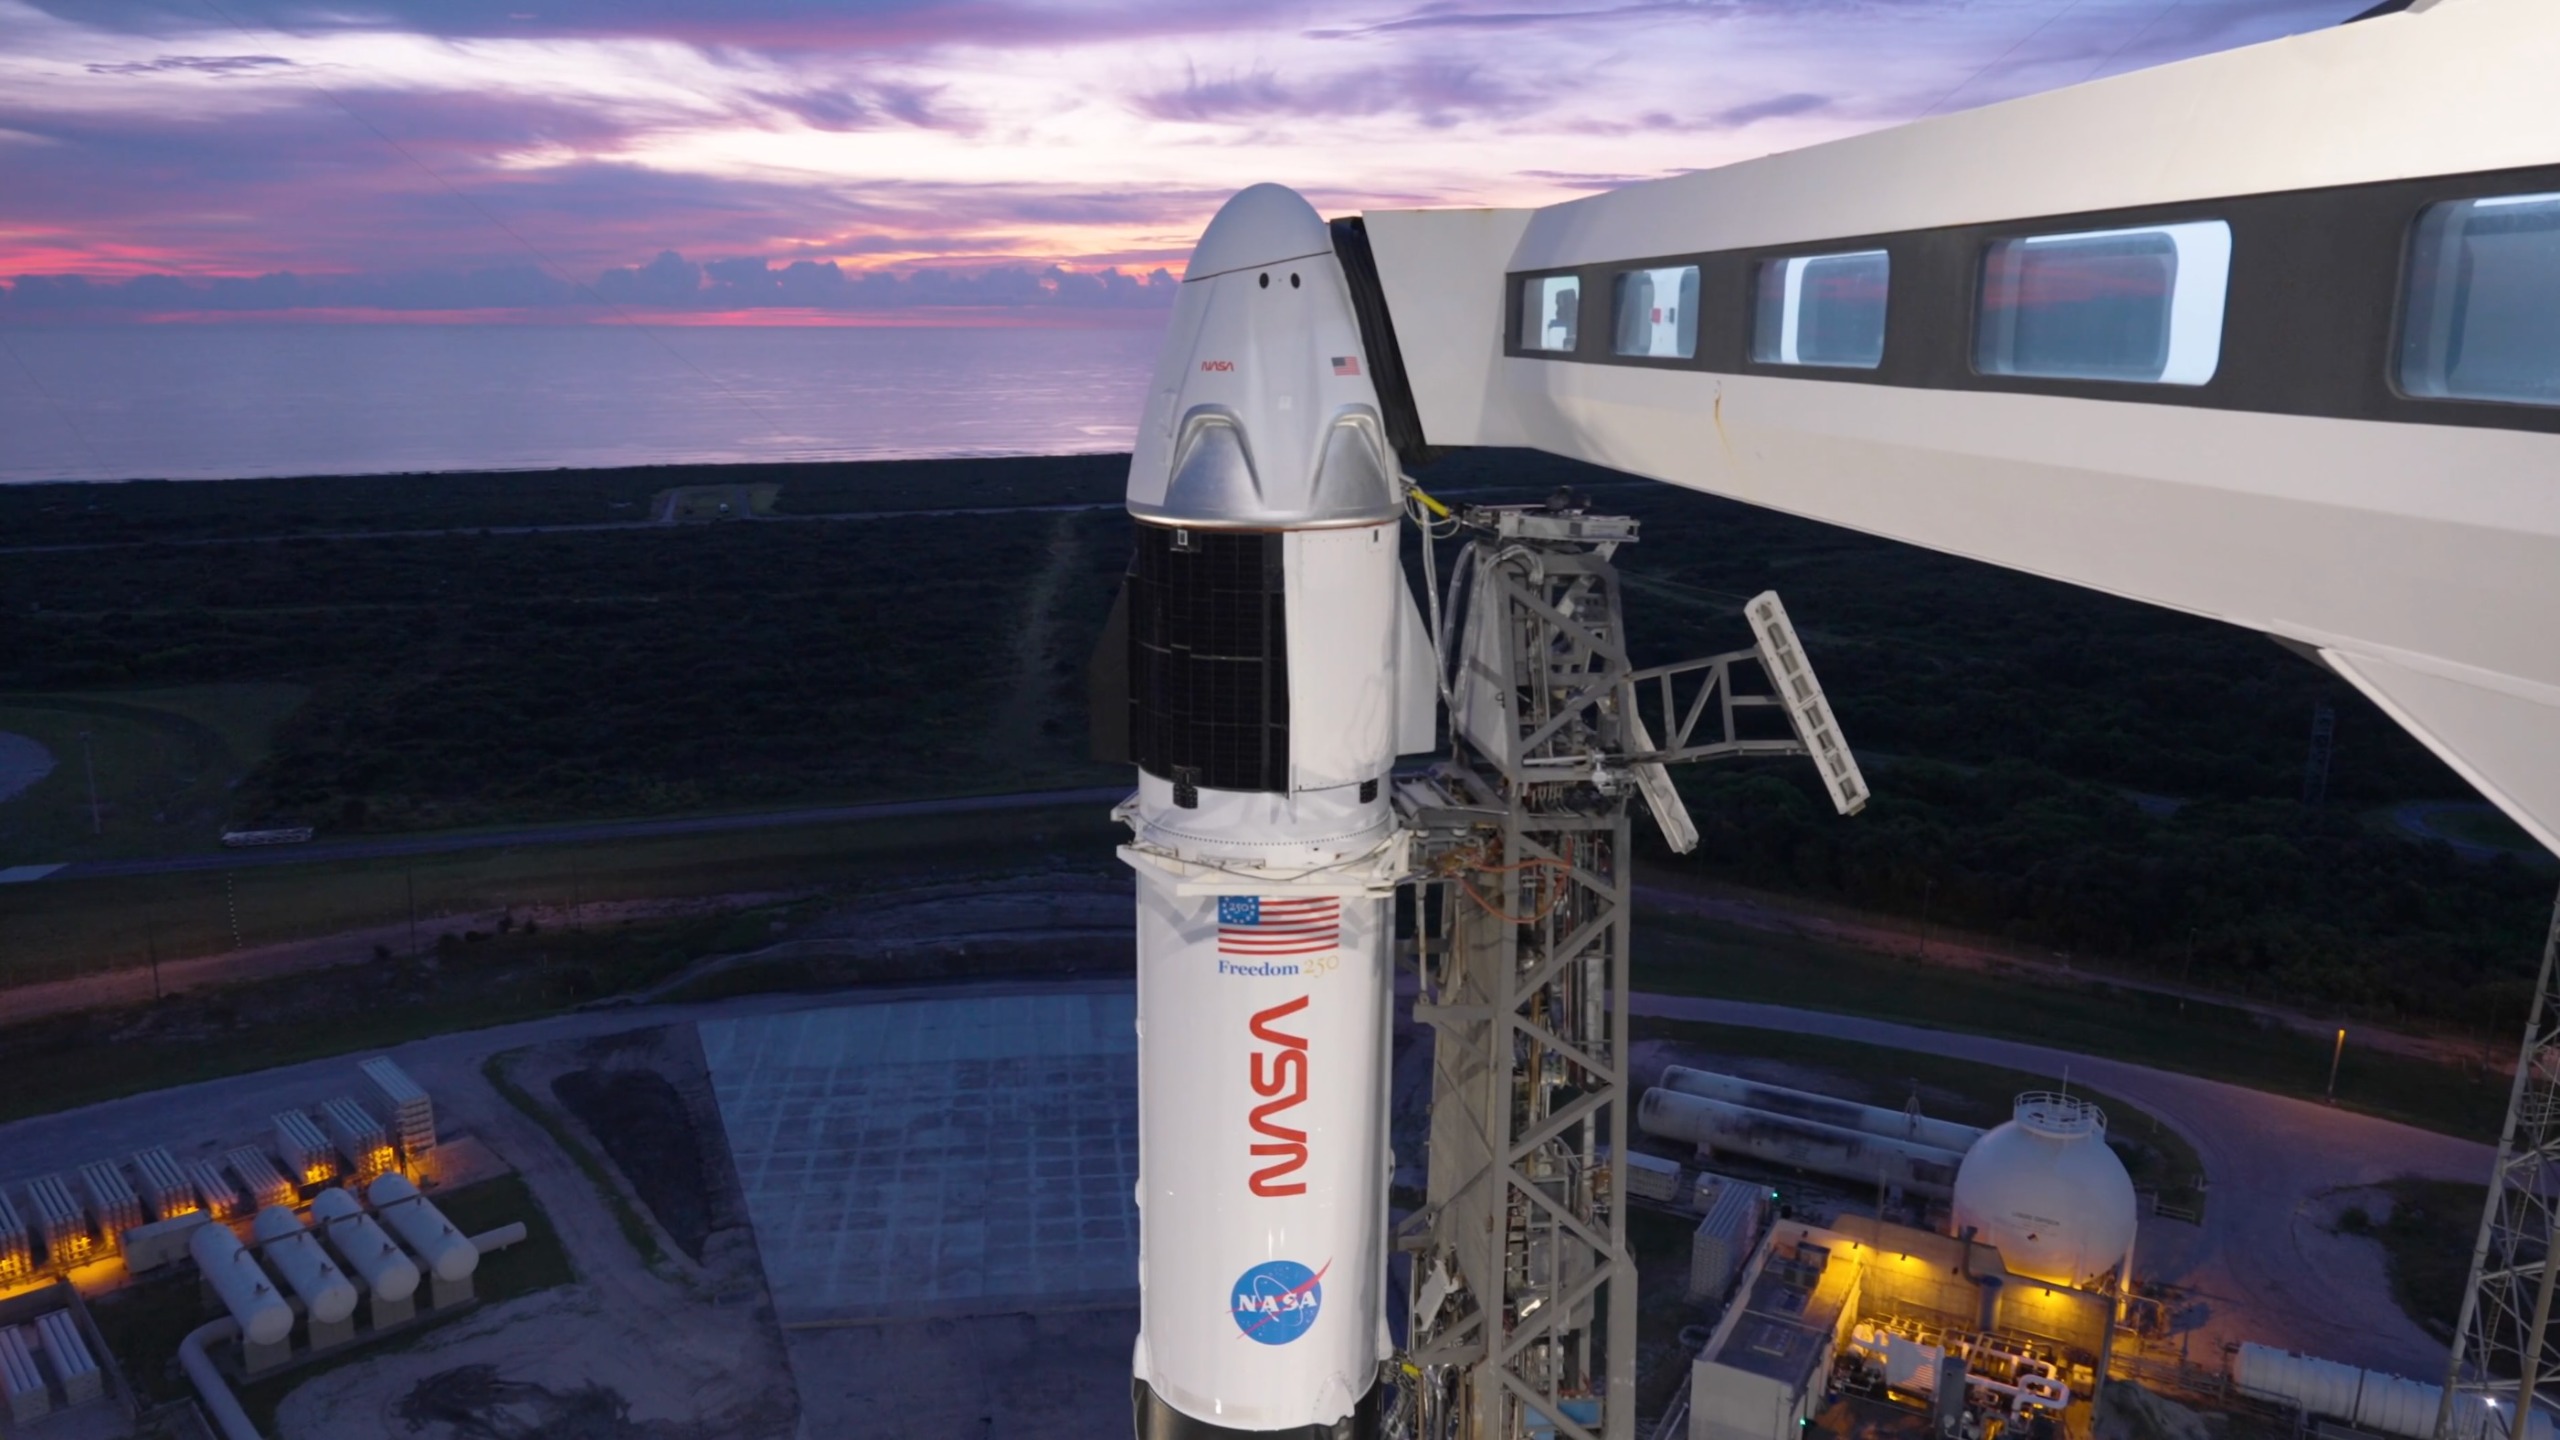
I spent the summer of 2026 at Space in Hawthorne, CA working with the Dragon Structures responsible engineer (RE) team. My work centered around reducing technical risk through improved analysis for NASA Crew-13 and future flights of Dragon capsules.
Developed test-based material allowables for complex composite sandwich flight hardware using FEMAP/NASTRAN to increase vehicle reliability
Designed automated tool leveraging part-specific data for individualized analyses, drastically reducing vehicle integration critical path time for hardware gapping residual stress analysis
Correlated integrated flight model to strain gauge test data for increased model fidelity and reduced technical risk
Designed and led torch testing campaign to validate thermal protection system change inmajor Crew Dragon exterior structures redesign
Designed go/no-gogauges for improving analysis input resolution and revised flight drawings/specifications(NX)
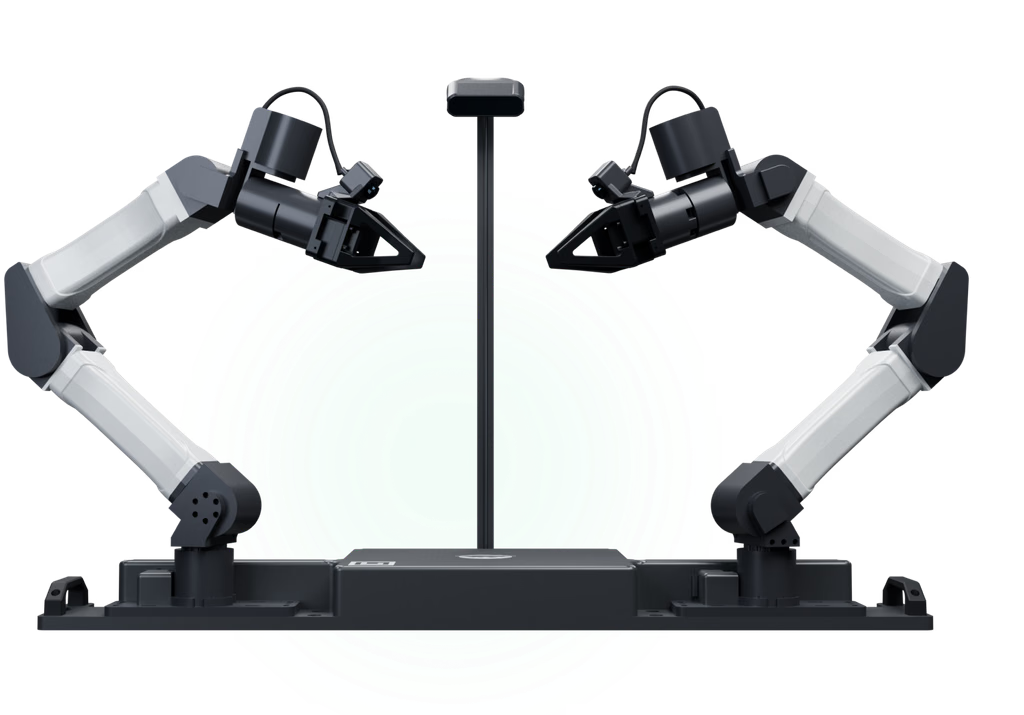
I developed a lightweight human-operated robotic data collection rig from initial prototype to five deployed operational units. I did extensive CAD and DFM work to optimize the units for accuracy, ease of assembly, and weight reduction
Designed and optimized exoskeleton robotic data collection rig in SolidWorks
Investigated failures in operational data collection units and improved component design
Optimized material selection based on design for manufacturing criteria
Developed work instructions for system-level assembly of human-operated robotic gripper
